Abstract
This is a reduced-order model of a chosen production-control policy, not a universal physical law of manufacturing. It separates physical work-in-process capacity, machine capacity, throughput-control gain, and adjustment lag. The circuit analogy helps derive transient and frequency responses; measurements must establish whether those responses describe a real line.
1. Scope and system boundary
Choose one production cell and count physical units from admission through completion. Q is admitted, unfinished physical WIP, including units waiting and being processed. Qmax is the cell’s total WIP limit, not just empty rack space. B is customer orders not yet admitted, counted in part-equivalents; those orders are not physical inventory. Demand λ creates orders, admission a releases available material, and throughput I completes it. Assume one homogeneous product, no scrap, no cancellations, and available raw material. All rates use parts/second; the demo uses parts/minute.
Queueing models and discrete-event simulation remain useful for variability, routing, blocking, and delivery reliability. This model complements them; it does not predict stockout probabilities or delivery-date distributions. MIT’s manufacturing variability lecture provides that broader context.
2. Independent measurements and policy choices
Four parameters have different jobs:
- Qmax [P]: the physical or chosen WIP limit.
- μ [P/s]: measured sustainable machine capacity; Reff = 1/μ is an effective cycle time.
- k [1/s]: independently chosen WIP-to-command gain. The throughput command is u = min(kQ, μ). It is a control policy, not a claim that machines naturally run proportionally to WIP.
- τL [s]: the lag from throughput command u to actual output I. Identify it using command and output data, with sufficient material and without capacity clipping.
For an isolated first-order command-to-output response, τL is the time to traverse 63.2% of the change. A demand-step response of the complete second-order loop does not directly give τL. Fit and validate the full model if that is the available experiment. See University of Michigan’s system-analysis tutorial. Measured parameters still have uncertainty; the model is not calibration-free.
3. The circuit model
3.1 Circuit coordinates
For the unsaturated interior, select a fixed reference quantity Qref and define V = Q/Qref, C = Qref, Rc = 1/(k Qref), and Lc = τL Rc. Then the parallel capacitor and series RL branch reproduce the equations below. Qref is a coordinate scale, not physical capacity; Rc is a controller-dependent analogue, not Reff. The quantity ½LcI² is a mathematical storage function, not a separately measured count of committed parts. Physical WIP is already counted in Q.
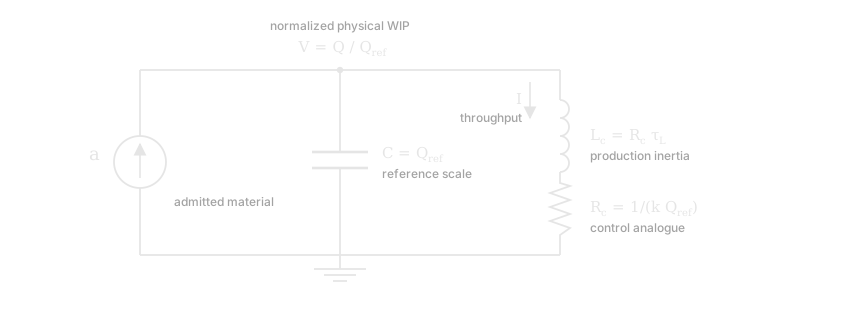
Figure 1. Circuit analogy for admitted material a and physical WIP Q. The coordinate scale and controller analogue are independent of the WIP limit.
3.2 Admission and saturation
Orders enter B first. Admit available material while orders and WIP space are available. At Q = Qmax, admission cannot exceed completions; at B = 0, it cannot exceed arriving orders. At Q = 0, output cannot exceed available admitted material. These boundary rules keep B ≥ 0 and 0 ≤ Q ≤ Qmax. They replace the linear model at the boundaries.
The throughput command is capped at μ, but actual output approaches it with lag. A full cell can command at most min(μ, kQmax). If kQmax < μ, the policy/WIP combination limits throughput before the equipment does. The former harmonic approximation λμ/(λ+μ) is removed: at λ = μ it gives μ/2, so it cannot represent the hard capacity limit.
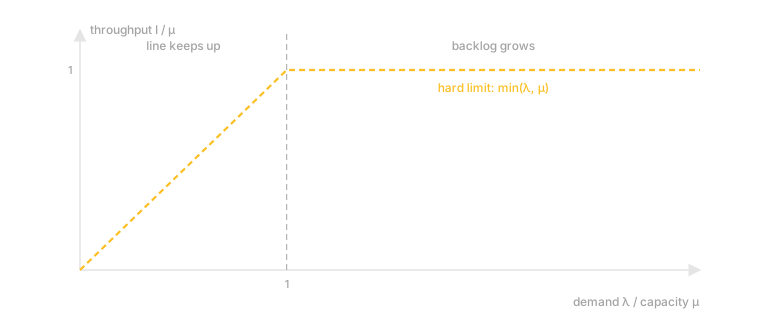
Figure 2. Steady throughput versus demand when kQmax ≥ μ. Below capacity the line can keep up; above capacity the order backlog grows. This is not an instantaneous response curve.
3.3 Second-order dynamics
Inside the boundaries, with no command clipping, the state equations and their linear transfer functions are below. These transfer functions describe perturbations around a feasible steady state, with zero perturbation initial conditions. Replace a by λ only when admissions track demand without backlog or material delay.
Changing Qmax alone changes headroom, not these poles or damping. The old formulas are recovered only by deliberately imposing k = μ/Qmax = 1/(Qmax Reff). Enlarging capacity under that rule also retunes the controller; it is not a pure storage change.
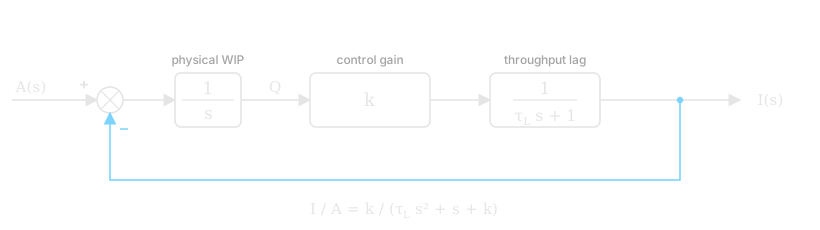
Figure 3. Admission minus completion accumulates as physical WIP. Gain k sets the throughput command, and the station responds with lag. The blue return is completed flow, not an extra stream of parts.
Watch the production line respond
Demand starts at 20 parts/min. At minute 0 it jumps to the selected rate. Follow the output as it catches up, and the work that accumulates while it lags.
The lesson: gain and lag set damping. Physical WIP space sets the admission limit. More space alone does not retune the line.
Output responds slowly, then overshoots demand. The buffer rises and falls as the line corrects itself.
Orders arrive → material is admitted when space opens → physical WIP → completions
The line is still producing at the old rate. Advance time to see what happens after the demand jump.
Time after demand change (min)
The amber line is what the line actually produces. The blue dashed line is what customers ask for. The gap is a rate mismatch, not lost work.
Time after demand change (min)
Amber is admitted physical WIP, including processing. Pink is orders not yet admitted, not inventory. The dashed line is the total physical WIP limit.
Illustrative §3.3 model: machine capacity 60 parts/min, initial Q = 20/k, independent control gain k. Raw material is available and admission is instantaneous when space opens. Q includes waiting and processing; B counts unadmitted orders. ζ = 1/(2√(kτL)) applies before saturation. Settings restart the run; fractional parts represent average flow.
4. Applications and limits
4.1 Frequency response and phase alignment
The quantity formerly called Manufacturing Power Factor is retained as MPF, a phase-alignment indicator. It is not an efficiency, service-level, or useful-production fraction. Oscillating throughput can still produce saleable parts; phase alone does not establish waste. Use atan2 to retain the phase quadrant.
AQ is WIP swing per unit admission-rate swing, in seconds. Its low-frequency value is 1/k. A sinusoidal input of amplitude Δa produces ΔQ = Δa AQ only while the whole trajectory remains unsaturated. As τL tends to zero, the residual lag is atan(ω/k); changing physical space alone does not change it.
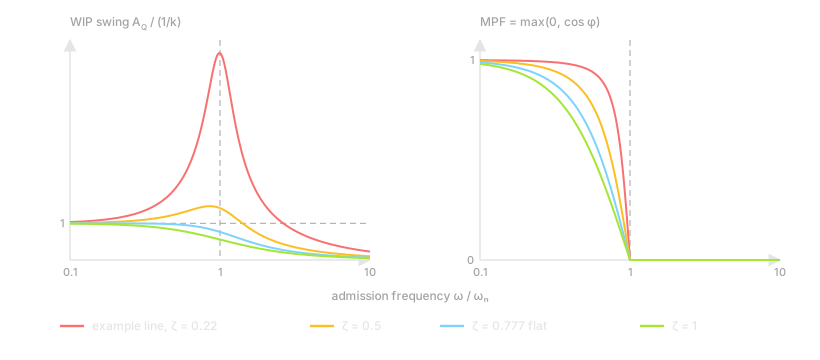
Figure 4. Left: WIP swing divided by 1/k. Right: phase alignment, not manufacturing efficiency. Damping ratios compare policies and lags in the unsaturated model.
4.2 Tune the gain, then size the WIP limit
The no-peak condition for AQ is ζ ≥ ½√(1+√2) ≈ 0.777. The numerator zero makes this different from the throughput-response threshold ζ ≥ 1/√2. Critical damping is ζ = 1. These are gain/lag conditions, not universal buffer-sizing rules.
Lowering k raises damping but also raises equilibrium WIP a*/k and slows the response. Reducing τL raises damping without changing equilibrium WIP when k stays fixed. A larger Qmax gives more headroom without changing either effect until a boundary is reached.
For one sinusoidal admission component, require both Q* − ΔQ ≥ 0 and Q* + ΔQ ≤ Qmax, and check the throughput command against μ. For steps, multiple frequencies, or random outages, calculate the full trajectory and validate the required margin. If you deliberately retain k = μ/Qmax, the old rule Qmax ≥ (1+√2) μτL is a joint sizing-and-retuning rule only.
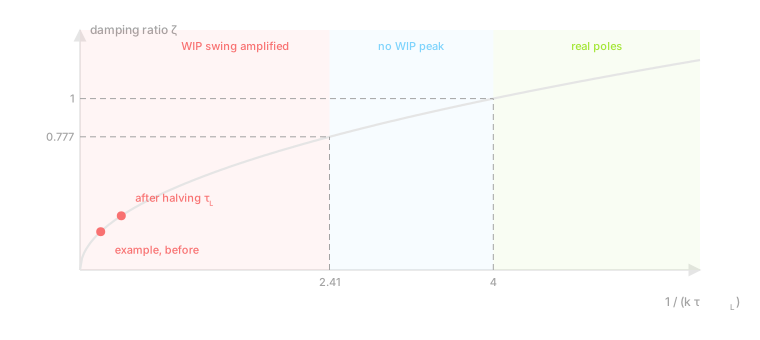
Figure 5. Damping versus 1/(kτL). Moving right means reducing gain or lag, not merely adding storage. Example points keep k fixed and halve τL.
4.3 Fill, drain, and outage coverage
For constant actual rates, time to fill during a downstream stop is (Qmax − Q)/a; time to drain during an admission stop is Q/I. The latter assumes output is held constant: the proportional policy otherwise reduces output as WIP falls. A planned outage needs available initial WIP at least Iout × tout to sustain that output, not just empty capacity. Iout = μ only for full-rate operation.
At an unsaturated equilibrium, the fill fraction is a*/(kQmax), not generally utilization a*/μ. They coincide only under the extra choice k = μ/Qmax.
4.4 Availability and machine capacity
With cycle time tc, parallel machines m, and available-time fraction D, use μ ≈ mD/tc as an average-capacity estimate and verify it against production data. Reff = tc/(mD). Keeping k and τL fixed means changing D changes the saturation limit, not the unsaturated poles. The old square-root dependence of natural frequency on D follows only if k is also scheduled as μ/Qmax. Explicit shift boundaries and failures require a time-varying availability model.
4.5 Batch processing needs its own assumptions
A fixed residence time alone is a pure delay, H(s) = exp(−sτ), with unit magnitude: it does not smooth fluctuations. The sinc curve below instead assumes a uniform averaging window of width τ. It can describe a specified averaging or staggered aggregation scheme, but does not follow automatically from “parts spend τ in an oven.” Real batch scheduling can require discrete-event modeling.
For N processors, b parts per batch and processing time τ, nominal capacity is Nb/τ, before downtime and loading losses. Launching one batch every Δt needs ceil(τ/Δt) simultaneously available processors. With τ = 84,807 s, b = 4, N = 2, capacity is about 8.15 parts/day. A launch interval of 17,300 s would require five processors and is infeasible with two; increasing the feed buffer cannot fix that shortfall.
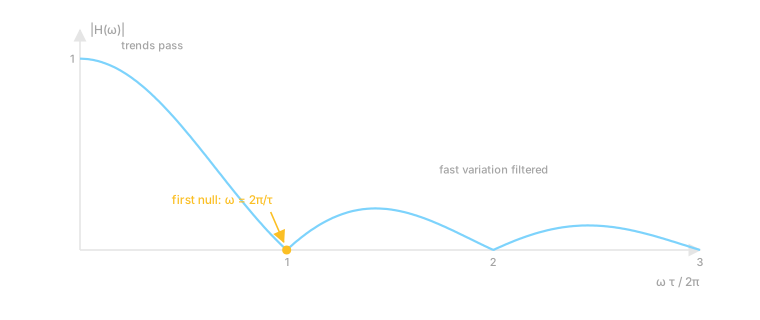
Figure 6. Uniform averaging response, conditional on that additional assumption. A fixed residence-time delay alone has no magnitude attenuation.
4.6 Costs and validation
An oscillation about a fixed mean does not, by itself, increase average WIP or prove wasted production. A carrying-cost estimate needs a measured or independently justified change in mean physical WIP, ΔQbar: savings = h × ΔQbar × T, with consistent time units. Do not price unadmitted orders B as if they were physical inventory. Quantify lateness or lost-sales costs separately.
A conditional ramp-cost model is Kramp = cramp × ΔI × Ncycles, where ΔI = Δa |I/A(jω)| and cramp is empirically calibrated. Reducing τL does not universally reduce ΔI: evaluate the transfer function at the relevant frequencies. Report net benefit after operating costs and implementation cost; financial returns are scenarios until validated.
Illustrative dynamics, not a savings forecast. Keep k = 10⁻⁵ s⁻¹, μ = 0.01 P/s, Qmax = 1,000 P, and mean admission 0.005 P/s. Q* = 500 P. With τL = 500,000 s, ζ ≈ 0.224; halving τL raises ζ to ≈ 0.316, while Q* and physical capacity stay unchanged. For ω = 2.4×10⁻⁶ s⁻¹ and Δa = 0.002 P/s, the predicted steady sinusoidal WIP amplitudes are about 420 P and 264 P. Both fit within the 0–1,000 P limit around that mean, but neither proves a reduction in mean stock or cash cost. These amplitudes assume a steady sinusoid; check startup transients separately.
Before using the model for decisions: identify μ and τL, record the actual control gain k and admission rule, compare predictions with held-out output/WIP data, and test boundaries, outages, and uncertainty. Validate the relationship between any proposed change and the cost it is supposed to reduce.